Stopping a drone begins before the jammer, interceptor or gun is used. The first problem is finding the aircraft early enough, tracking it reliably enough and identifying it confidently enough for a defender to decide what to do next.
That sounds straightforward until the target is a small unmanned aircraft flying low, moving against cluttered terrain, using little or no radio transmission and presenting a much smaller signature than the aircraft traditional air-defence systems were designed to watch.
This is why modern counter-UAS systems rarely rely on one sensor. Radar, radio-frequency detection, electro-optical and infrared cameras, and acoustic arrays each observe a different part of the problem. Their strengths overlap, their blind spots do not, and the most capable systems increasingly fuse several of them into one operational picture.
Detection is not the same as identification
Counter-drone discussions often compress several different tasks into the word detection.
A sensor may first indicate that something is present. The system then has to maintain a track as the object moves. It may need to classify the object as a drone rather than a bird, aircraft, vehicle or environmental artifact. Finally, the defender may need enough confidence to identify the track as friendly, unknown or hostile before an effector is assigned.
NATO's counter-UAS experimentation treats these as distinct parts of an engagement chain. During TIE 26, NCIA assessed systems using criteria including track stability, sensor-to-command-and-control integration, identification performance and overall engagement-chain effectiveness. The emphasis is important: a brief detection that cannot be maintained or classified may have little operational value.
The practical problem is therefore not simply 'Can the sensor see a drone?' It is 'Can the defensive network turn that observation into a trustworthy track fast enough to support a decision?'
| Stage | Question | What can go wrong |
|---|---|---|
| Detect | Is there an object of interest? | Small signatures can be lost in terrain, weather, RF noise or visual clutter. |
| Track | Can the system keep following it? | Tracks can drop, split, merge or become ambiguous as the target manoeuvres. |
| Classify | Is it actually a drone? | Birds, aircraft, vehicles and other objects can create similar sensor cues. |
| Identify | What kind of track is it? | The system may know an object is a drone without knowing its model, operator or intent. |
| Cue | Which sensor or effector should look next? | Poor data sharing can make a valid detection arrive too late to matter. |
Why small drones are difficult targets
Traditional air-surveillance systems were designed around aircraft with relatively large radar, thermal and visual signatures. Small UAS invert many of those assumptions.
Their physical size can reduce the amount of energy returned to a radar. Low-altitude flight places the target against terrain and buildings rather than a clean sky background. Slow speed can place some drones close to the motion patterns of birds or environmental clutter. Commercial components and rapidly changing airframes also make signature libraries less stable than they are for conventional aircraft.
The problem becomes harder in cities and near military positions. Buildings obstruct line of sight. Vehicles and machinery add acoustic and electromagnetic noise. Friendly drones may be operating in the same airspace. A sensor that performs well on an open range can face a much less orderly picture in a dense operational environment.
The result is a detection problem defined by trade-offs. Sensors can be tuned to become more sensitive, but greater sensitivity can generate more false alarms. A longer detection range can be useful, but only if the system can still maintain a reliable track and distinguish the target from clutter.
Radar: the active search layer
Radar remains one of the most important counter-UAS sensors because it can search a volume of air continuously and measure the position and motion of objects without waiting for them to transmit.
That independence from the drone's radio link is a major advantage. A radar can potentially detect a remotely piloted aircraft, an autonomous aircraft or a fibre-optic-controlled aircraft because the sensor is observing the physical target rather than its communications.
Small-UAS radar is not simply conventional air-defence radar scaled down. The system has to work much closer to terrain and distinguish low-signature targets from birds, vegetation, ground traffic and other clutter. Modern systems therefore rely heavily on signal processing and classification algorithms in addition to raw radar energy.
Radar's strength is persistence and geometry: it can provide range, bearing and movement information that makes it valuable for cueing other sensors. Its weakness is that a radar return by itself may not tell an operator exactly what the object is.
That makes radar especially useful as the beginning of a multi-sensor chain. It finds and tracks; another sensor may then help confirm identity.
RF detection: listening for the drone's electronic activity
Radio-frequency sensors solve the problem from a different direction. Instead of looking for the aircraft as a physical object, they listen for emissions associated with the drone, its controller, video link or other radio-dependent systems.
Because RF detection can be passive, the sensor does not have to radiate energy to search. Depending on the system and the signal available, RF sensing can provide warning, classification information and direction finding that helps locate the source of a transmission.
The advantage is information richness. A detectable radio link can sometimes reveal characteristics that a radar return cannot. The limitation is equally fundamental: an RF detector only sees what is transmitting in a form it can observe.
This matters more as drone communications diversify. Fibre-optic FPVs move the command/video link out of the radio spectrum. Autonomous functions can reduce continuous operator communication. Frequency changes and unfamiliar waveforms can also challenge systems that depend on known signal libraries.
U.S. counter-UAS officials have explicitly warned against relying on RF alone. In an August 2026 Army media roundtable, JIATF-401 officials described cameras, radars, acoustic sensors and other commercial components as necessary parts of layered detection while noting that the threat is moving beyond familiar RF bands and conventional control links.
EO/IR: putting eyes on the track
Electro-optical and infrared sensors provide something radar and RF systems often cannot: an image of the target.
Daylight cameras can help an operator or computer-vision system visually classify a drone once another sensor has pointed the camera toward the correct part of the sky. Infrared imaging adds another channel by observing thermal contrast, which can be useful at night or when visible-light conditions are poor.
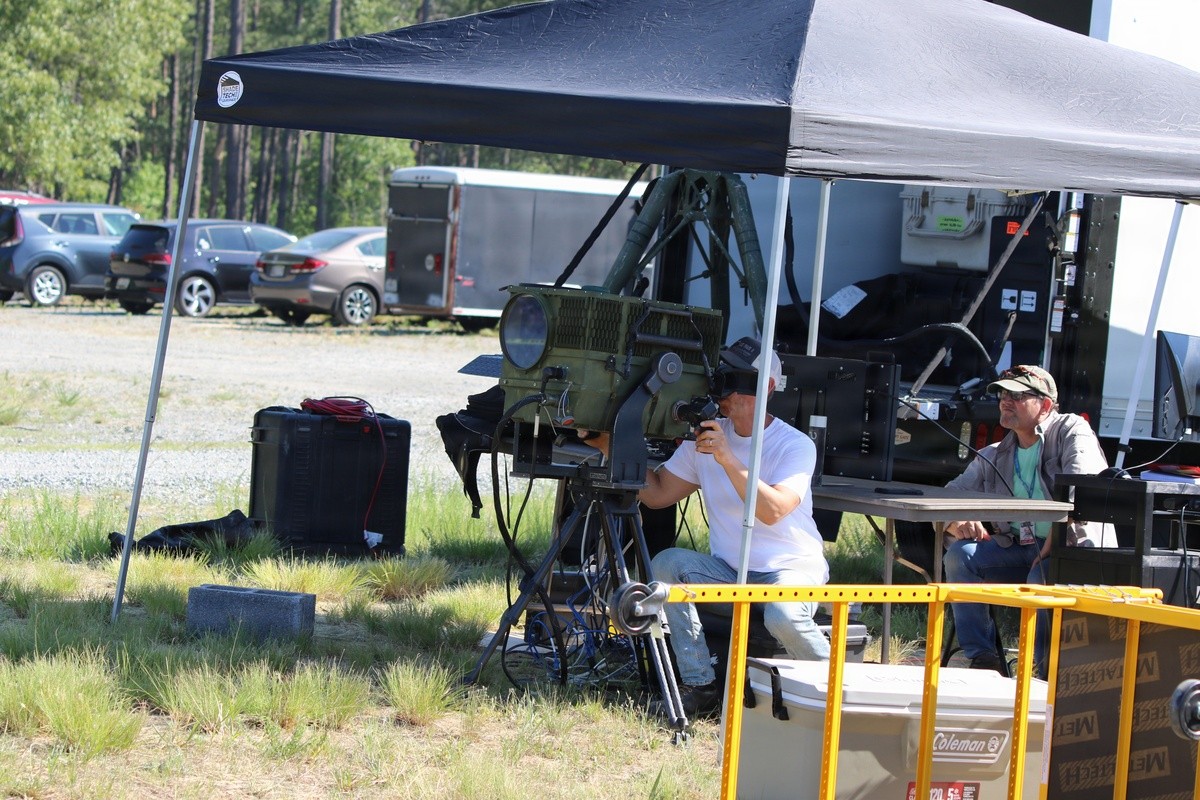
This makes EO/IR particularly valuable for identification and confirmation. A radar may report a small moving object. An RF sensor may indicate a transmission. A camera can provide the visual evidence needed to decide that the object is actually an unmanned aircraft.
The limitation is geometry. Cameras depend on line of sight and have a relatively narrow field of view compared with a wide-area search radar. Weather, haze, background contrast and range can all reduce what an optical system can resolve.
For that reason, EO/IR often works best as a cued sensor rather than the only search layer: another system detects and tracks broadly, then the camera is pointed toward the track for confirmation.
Acoustic detection: listening for propulsion and flight signatures
Acoustic sensing turns the drone's own sound into a detection channel.
Arrays of microphones can listen for characteristic propulsion and rotor signatures. Because acoustic systems are passive, they can add coverage without transmitting radio or radar energy. Distributed networks can also create early warning across a wide area when many low-cost nodes are deployed together.
Ukraine has provided some of the clearest examples of this approach. A 2026 U.S. Army paper on acoustic drone detection examined Ukrainian networks including Sky Fortress, Zvook and FENEK, describing the use of large numbers of passive sensors to identify drone signatures and cue local defence.
Acoustic sensing has obvious limitations. Wind, traffic, machinery, weapons fire and urban noise can mask or confuse signatures. Sound also propagates differently with terrain and atmospheric conditions. It is therefore better understood as another layer of evidence than as a universal replacement for radar.
Its attraction is economic. A low-cost acoustic network can extend warning coverage and provide another independent cue that can be fused with more expensive sensors.
| Sensor | Primary observation | Main strength | Main limitation |
|---|---|---|---|
| Radar | Physical target and motion | Wide-area search and persistent tracking without depending on drone emissions | Small targets and ground clutter make classification difficult. |
| RF / direction finding | Radio emissions | Passive detection can provide rich signal and directional information | Cannot dependably detect drones that do not emit an observable radio signal. |
| EO / visible camera | Visual image | Strong confirmation and classification when the target is in view | Line of sight, weather, background and field of view constrain search. |
| IR / thermal | Heat contrast | Useful for night operations and complementary visual confirmation | Small thermal signatures and environmental conditions can reduce contrast. |
| Acoustic | Sound signature | Passive and potentially inexpensive to distribute over large areas | Noise, terrain and atmospheric conditions complicate detection. |
Sensor fusion is the real capability
The strongest trend in drone detection is therefore not a competition to find one perfect sensor. It is the fusion of imperfect sensors.
NCIA's September 2026 Counter-UAS Data Challenge states the problem directly: reliably detecting and identifying small drones requires combining radar, RF detectors, cameras and acoustic systems, then turning those fragmented inputs into a coherent air picture.
This can work because the weaknesses are different. Radar may detect an object that is silent in the RF spectrum. RF detection may provide an early directional cue before an optical sensor has acquired the aircraft. An acoustic node may alert the network to a low-altitude target obscured by terrain. A camera may then confirm what the other sensors only inferred.
Fusion also helps manage false alarms. A single ambiguous radar return may not justify action. A radar track that aligns with an acoustic signature and an optical detection is more informative. The system does not make uncertainty disappear; it combines independent evidence to improve confidence.
The technical challenge is ensuring those sensors describe the same object consistently and quickly. They may update at different rates, use different coordinate systems and produce different levels of confidence. A useful counter-UAS C2 layer has to reconcile those inputs into tracks that operators and effectors can use.
The common air picture matters as much as the sensor
This is why NATO increasingly describes counter-UAS as an integration problem.
NSPA's 2026 framework contracts for tactical C-UAS are built around a common C2 backbone capable of integrating radar, direction-finding, EO/IR and acoustic sensors together with electronic-warfare and hard-kill effectors. NATO ACT's Layered Counter-UAS Initiative follows the same logic at a broader level: connect sensors, decision-making and effectors instead of treating each counter-drone cell as an isolated island.
NCIA's TIE 26 testing placed particular emphasis on sensor-to-C2 integration and track stability. In other words, a high-performance sensor that cannot share usable data with the rest of the defensive network can be less valuable than a somewhat less capable sensor that integrates cleanly.
This changes procurement. The buyer is no longer selecting only a radar or only a camera. It is selecting a node in a larger information architecture.
Active and passive sensors solve different operational problems
Another useful distinction is whether the sensor emits energy.
Radar is an active sensor: it transmits energy and measures returns. RF receivers, cameras and microphones can operate passively. Passive systems have an obvious advantage when a defender wants to observe without adding its own emission to the environment.
But passivity does not automatically make a sensor superior. A passive RF detector cannot observe a useful signal if the target is radio-silent. A camera cannot see through an obstruction simply because it is passive. An acoustic array cannot create a reliable track when the sound is masked.
The useful question is therefore not active versus passive in isolation. It is which combination of sensors provides enough coverage and confidence for the defended environment.
DOCUMENTNCIA describes the challenge of fusing radar, RF, camera and acoustic data into a single coherent air picture.OPEN ↗The environment determines which sensor matters most
A counter-UAS sensor layout that works around an airfield will not necessarily be optimal in a city, on a forested front line or around a mobile military formation.
Open terrain can favor longer sight lines. Urban environments introduce buildings, reflections, dense RF activity and acoustic noise. Forest and terrain can obstruct both radio and visual paths. A mobile force cannot always carry the same sensor suite as a fixed installation.
The U.S. Army's passive-detection research explicitly allows for degraded performance in wooded and dense metropolitan environments. That acknowledgement is important because detection ranges quoted under controlled conditions can become misleading when presented as universal battlefield performance.
For the same reason, responsible comparison of counter-drone sensors should look beyond a single maximum range figure. Field of view, update rate, false-alarm behavior, classification quality, weather tolerance, mobility and integration all affect how useful the sensor is in practice.
Fibre-optic and autonomous drones are changing the sensor mix
The spread of fibre-optic FPVs demonstrates why counter-UAS detection cannot remain tied to one signature.
A drone whose control and video path runs through a physical fibre does not present the same RF opportunity as a conventional radio-controlled FPV. NATO's 2025 innovation work on countering fibre-optic drones therefore emphasized radar, thermal, acoustic and optical detection alongside tracking and neutralization.
Autonomy creates a related challenge. If a drone can navigate or complete part of a mission without continuous radio control, the absence of a familiar command link does not mean the aircraft is absent.
The strategic implication is straightforward: sensor diversity becomes more valuable as drone architectures diversify. Every time an aircraft removes one observable dependency, defenders need other ways to detect and track the physical target.
AI is increasingly being used to reconcile imperfect sensors
Artificial intelligence in counter-UAS detection is less about a machine independently deciding that a drone is hostile and more about managing data that would otherwise overwhelm operators.
Different sensors generate different streams: radar tracks, RF detections, images, thermal signatures and acoustic events. Machine-learning systems can assist with classification, correlate signals and help decide whether separate observations represent the same physical object.
DOCUMENTNSPA describes a common C2 backbone integrating radar, direction finding, EO/IR and acoustic sensors with multiple effectors.OPEN ↗NCIA's 2026 data challenge is built around this fusion problem. Participants are being asked to use operational data from multiple sensors to create a single coherent air picture for faster and more reliable decision-making.
The important word is assist. Sensor fusion does not eliminate uncertainty, and automated classification can still be wrong. In defended airspace containing friendly drones, civilian aircraft, birds and other objects, confidence and traceability matter as much as speed.
Detection has its own economics
The economics of counter-UAS are often discussed in terms of the weapon used to defeat a drone. Detection has an economic problem of its own.
A defender may need to monitor a very large area continuously against threats that are individually inexpensive. Covering every possible approach with high-end sensors can become financially and logistically difficult.
This is one reason layered sensing is attractive. Lower-cost acoustic or RF nodes can provide distributed warning; radar can maintain tracks across larger sectors; EO/IR can be cued only when confirmation is needed. The exact architecture varies, but the principle is to spend sensor performance where it produces the most useful information.
The U.S. Army's 2026 discussion of homeland counter-UAS described many of these components — cameras, day/night optics, acoustic sensors and radars — as dual-use commercial technologies. That industrial base can make it easier to distribute sensing widely than would be possible with traditional military-only air-surveillance equipment.
What a mature drone-detection system looks like
The mature architecture is not a box labelled 'drone detector.'
It is a network.
Several sensor types search the environment. Their detections enter a command-and-control layer. Tracks are correlated and classified. Operators receive a common picture rather than separate screens for every sensor. The system then cues the most appropriate confirmation sensor or defensive effector.
This architecture also has to scale. NATO ACT is experimenting with linking multiple counter-UAS cells into a larger mosaic so that detections and decisions are not trapped inside individual defended sites. That moves the problem from local gadget integration toward an air-defence network.
The value of the network is not that every sensor sees every target. It is that the system can continue to function when one sensor does not.
The right way to understand drone detection
There is no universally best drone sensor.
Radar is powerful because it does not require the target to transmit. RF detection can reveal electronic activity passively. EO/IR provides visual confirmation. Acoustic arrays can add inexpensive passive coverage. Each sensor sees a different signature and inherits a different set of blind spots.
The decisive capability is therefore the ability to combine them.
Modern counter-UAS detection is becoming a problem of multi-sensor fusion, track management and command-and-control as much as a problem of hardware. The target is small, the environment is noisy and the defensive timeline is short.
Finding the drone is no longer one sensor's job. It is a network's job.